Grounded in real work
Real demonstrations anchor the geometry, objects, and task context behind each digital workcell.
THE DATA LAYER FOR PHYSICAL AI
Real-world demonstrations ground our digital twins.
Our goal: scalable synthetic episodes for robot learning.
Discuss a pilot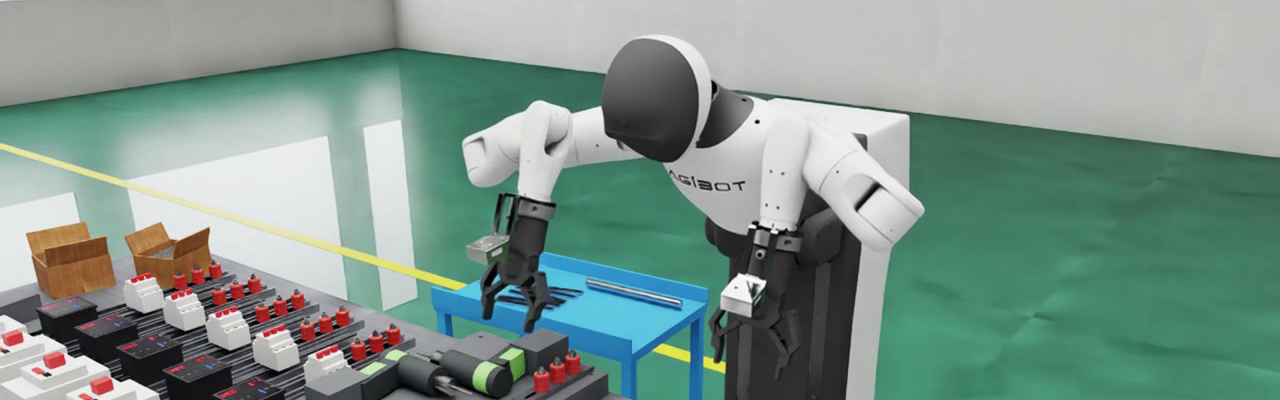
01 / THE DEMO
Real demonstrations anchor geometry and task context. Our prototype brings the workcell into a digital environment for comparison and iteration.
WATCH THE WORKCELL DEMO
Compare the real demonstration with the reconstructed robot view and the digital twin in motion.
A worker handles rails and components at a factory workbench. The upper panels compare real head-camera footage with the reconstructed robot-eye view. The lower panel shows a humanoid robot carrying out the scripted task sequence in the digital workcell. This video demonstrates reconstruction and scripted kinematics; it does not establish physics or training-data validation.
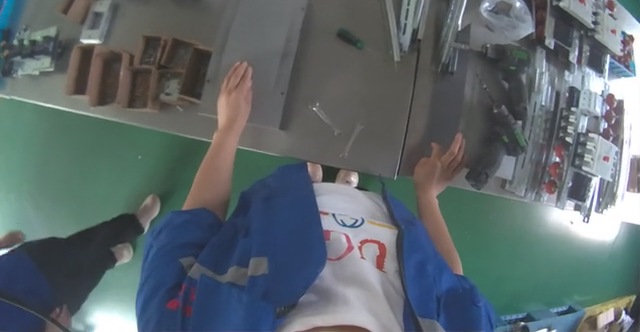
The real-world task and workcell
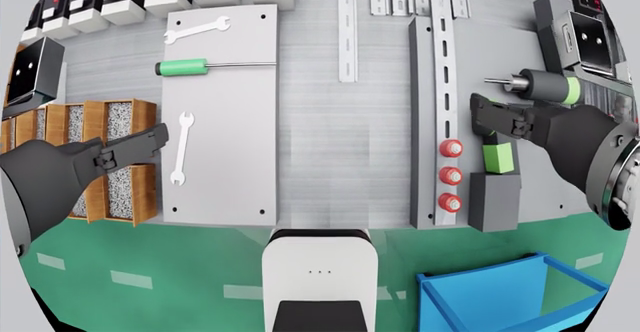
The task in a digital environment
A real-to-digital-twin comparison using scripted kinematics. Physics validation and validated training episodes remain on the roadmap.
02 / OUR APPROACH
A development workflow from real demonstrations to reusable workcells and, ultimately, validated robot-training data.
Start with real work, real geometry, and task context.
Use generative AI workflows to reconstruct the workcell.
Bring the digital twin closer to its real-world reference.
Reuse the digital workcell to explore new task variations.
Work toward validated episodes and recovery-data loops.
03 / WHY MERIT
Built for robotics and embodied AI teams developing a more capable physical AI future.
Real demonstrations anchor the geometry, objects, and task context behind each digital workcell.
Reusable workcells support new tasks and variants. Generative AI workflows aim to lower creation and data-generation costs.
Our approach puts rights, provenance, and quality checks at the center of data delivery.
BUILD WITH MERIT
Explore a workcell pilot, discuss a data need,
or learn more about our approach.
Workcell setup + recurring data contracts
Roadmap: subscription + generation usage